Computer Science

The Five Layers Reference Model

The Five Layers Reference Model in Computer Network

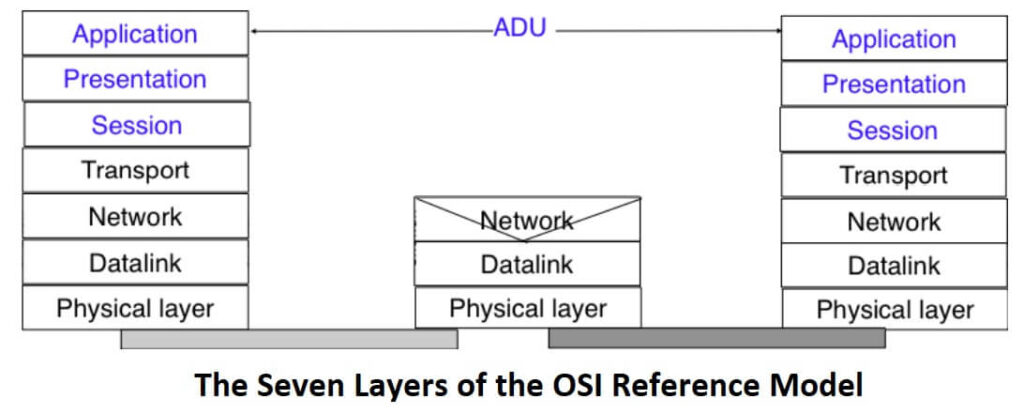
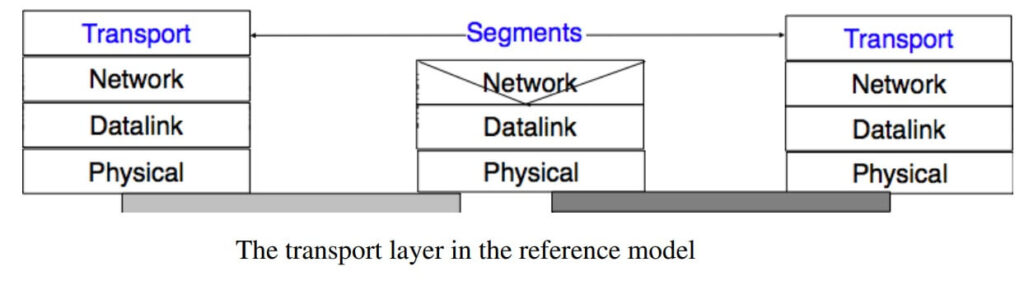
Our reference model is divided into five layers, as shown in the figure below. Starting from the bottom, the first layer is the Physical layer. Two communicating devices are linked through a physical medium. This physical medium is used to transfer an electrical or optical signal between two directly connected devices. Several types of physical

The Five Layers Reference Model in Computer Network Read More »

The Textual Robot Language

The Textual Robot Language – Pedagogy Zone

The first textual robot language was WAVE, developed in 1973 as an experimental language for research at the Stanford Artificial Intelligence Laboratory. Research involving a robot interfaced to a machine vision system was accomplished using the WAVE language. The research demonstrated the feasibility of robot hand-eye coordination. Development of a subsequent language began in 1974

The Textual Robot Language – Pedagogy Zone Read More »

Class Template with Overloaded Operators

The class template can also be declared for a class having operator overloaded member functions. The syntax for declaring operator overloaded functions is the same as class template members and overloaded functions. //template class for operator overloading complex class #include <iostream.h> template<class T> class Complex { T real, T imag; void getdata() { cin>>real>>imag ;}

Class Template with Overloaded Operators Read More »