A 4-Degree of Freedom Manipulator in Three Dimensions
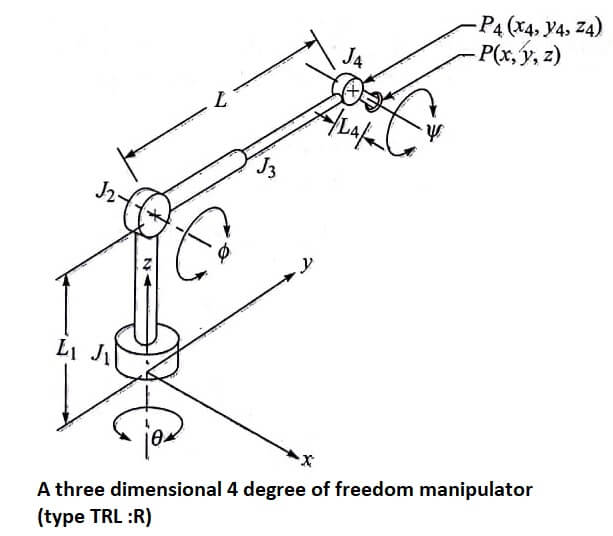
Figure illustrates the configuration of a manipulator in three dimensions. The manipulator has 4 degrees of freedom: joint 1 (type T joint) allows rotation about the z axis; joint 2 (type R) allows rotation about an axis that is perpendicular to the z axis; joint 3 is a linear joint which is capable of sliding
A 4-Degree of Freedom Manipulator in Three Dimensions Read More »