Reverse Transformation of the 2-Degree of Freedom Arm
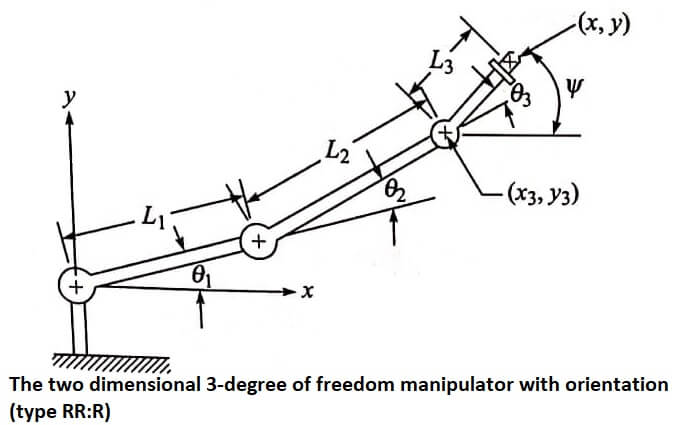
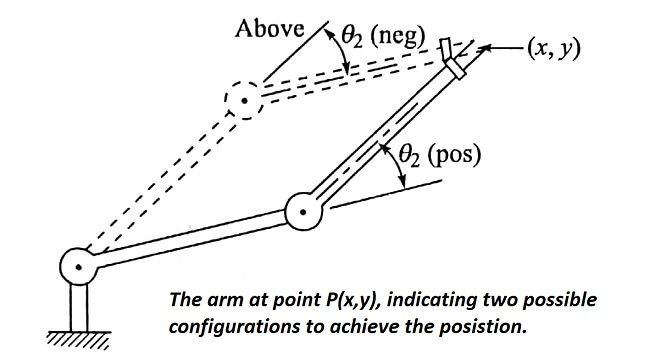
In many cases it is more important to be able to derive the joint angles given the end-of-arm position in world space. The typical situation is where the robot’s controller must compute the joint angles required to move its end-of-arm to a point in space defined by the point’s coordinates. For the two-link manipulator we
Reverse Transformation of the 2-Degree of Freedom Arm Read More »